ASCENSION ROBOTICS
Building the Future, One Robot at a Time
Our Mission
To develop the next generation of robotics engineers by designing, building and coding advanced robots for one of the most technically-demanding engineering competitions.
What is RoboMaster?
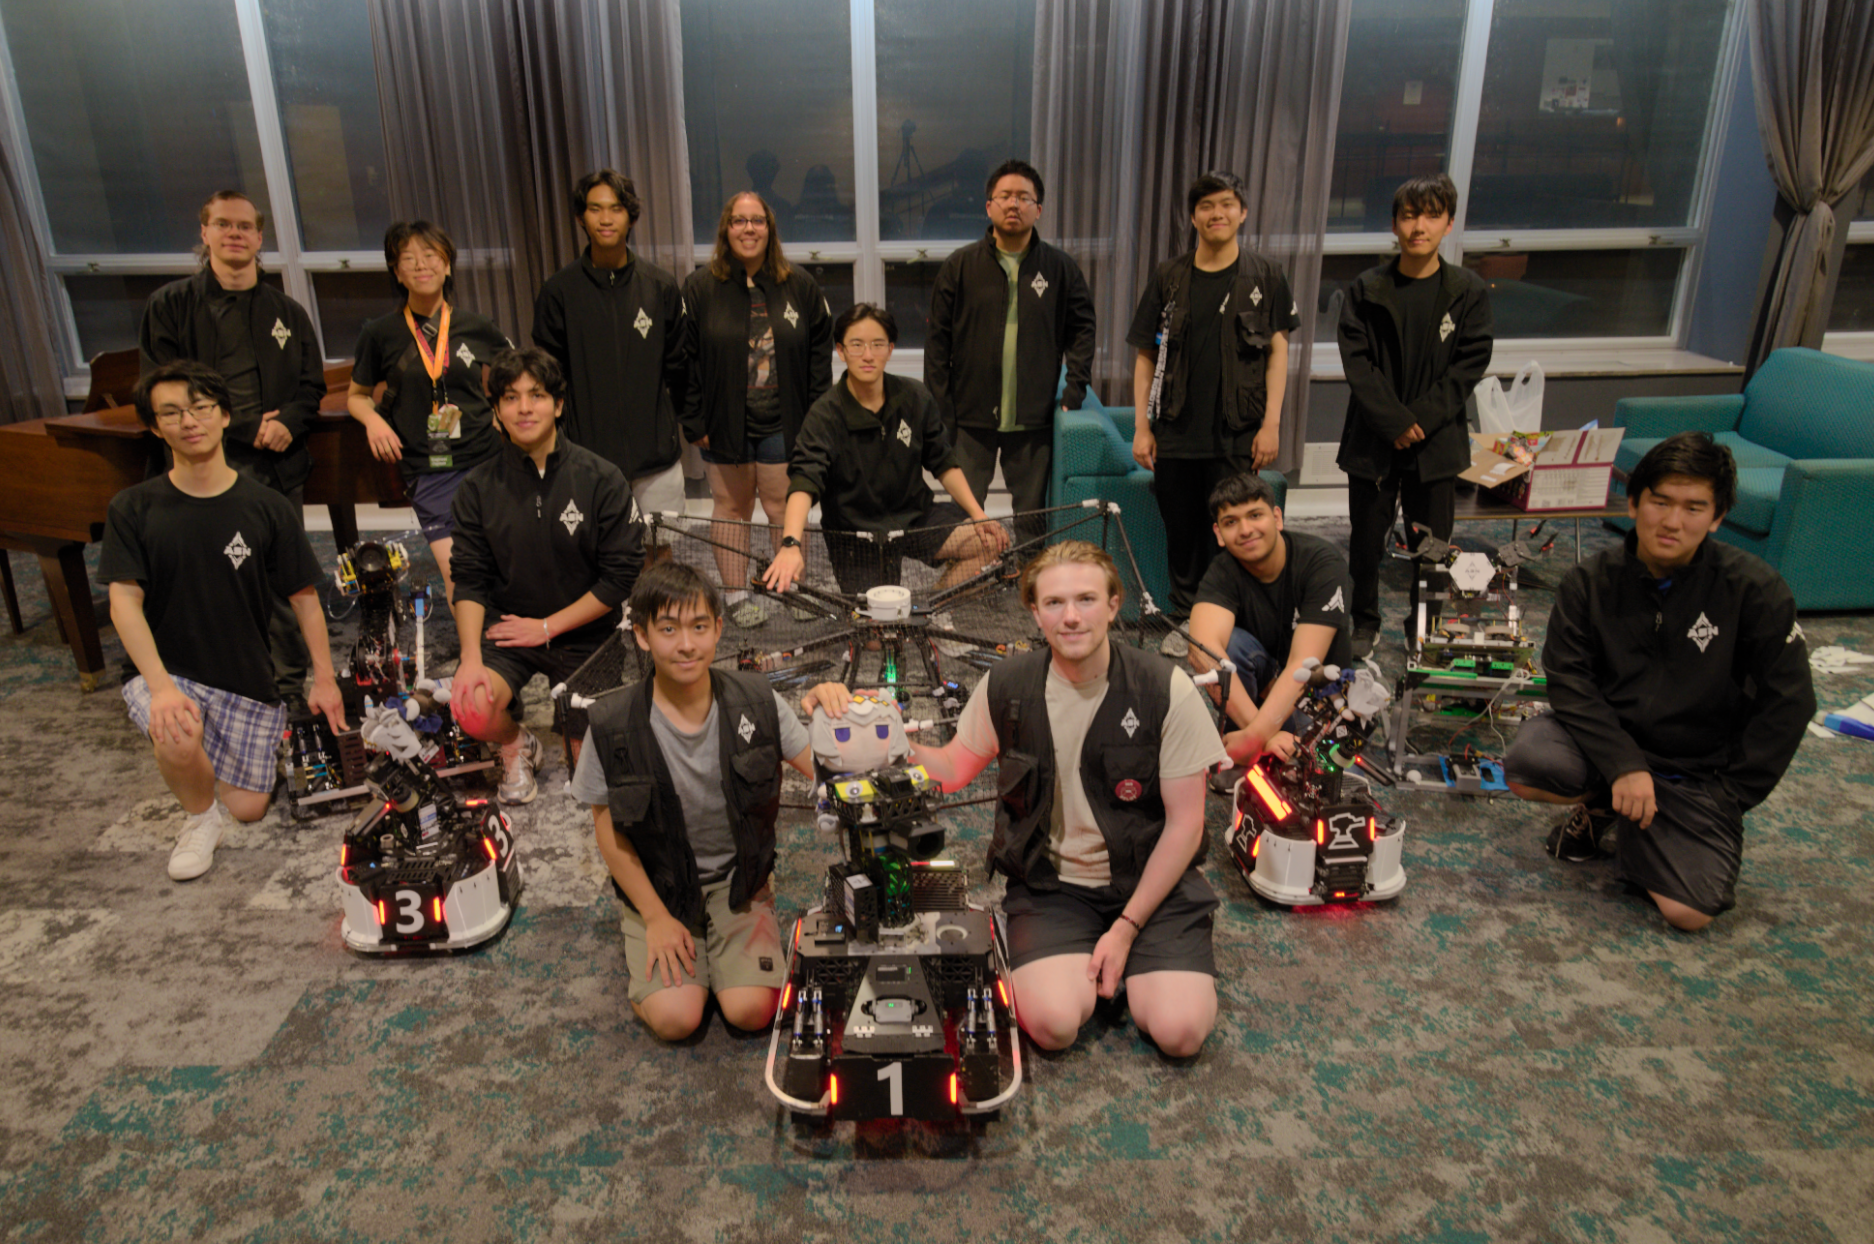
RoboMaster is a robotics competition that blends engineering, programming, and competitive gameplay. Teams design, build, and program custom robots that engage in dynamic battles on a specialized battlefield. The objective is to score points by firing projectiles at opponent robots and designated targets while protecting their own base.
At Ascension Robotics, we combine expertise in mechanical design, electronics, and software development to engineer robots for the RoboMaster competition. Join us as we shape an exciting future for our team!
Design
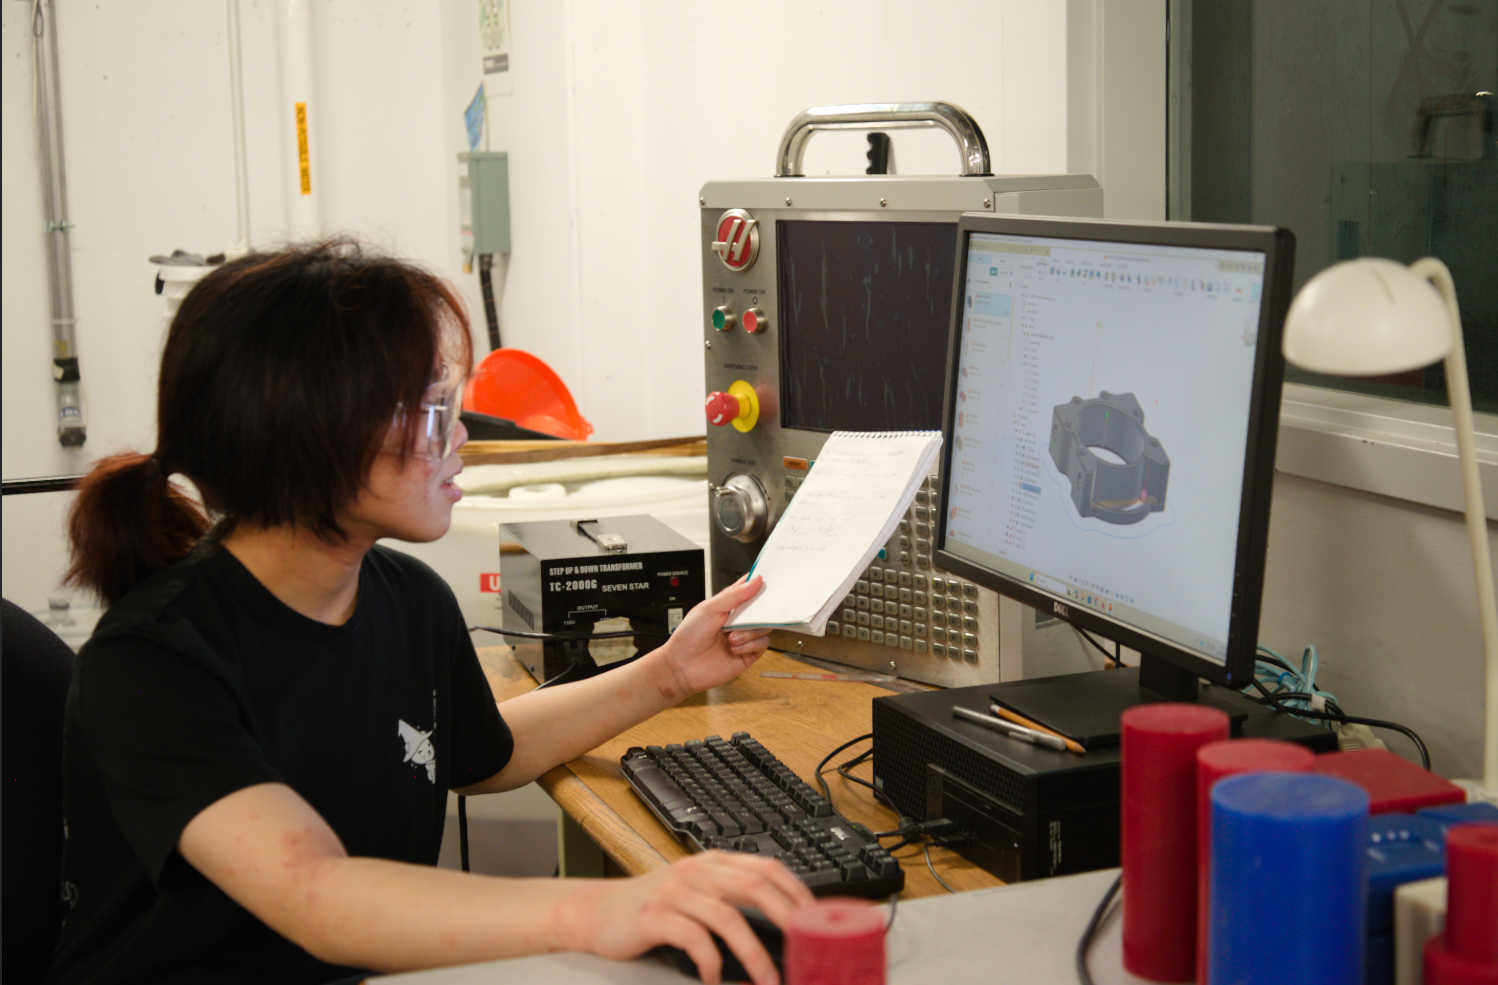
The design team collaborate on initial ideas through hand-drawn sketches and concept discussions before developing detailed CAD models in SOLIDWORKS and other design software. These models are transformed into precise prototypes, often 3D printed for rapid testing and refinement. Through iterative feedback, designs are improved to ensure optimal performance before final manufacturing.
Fabrication
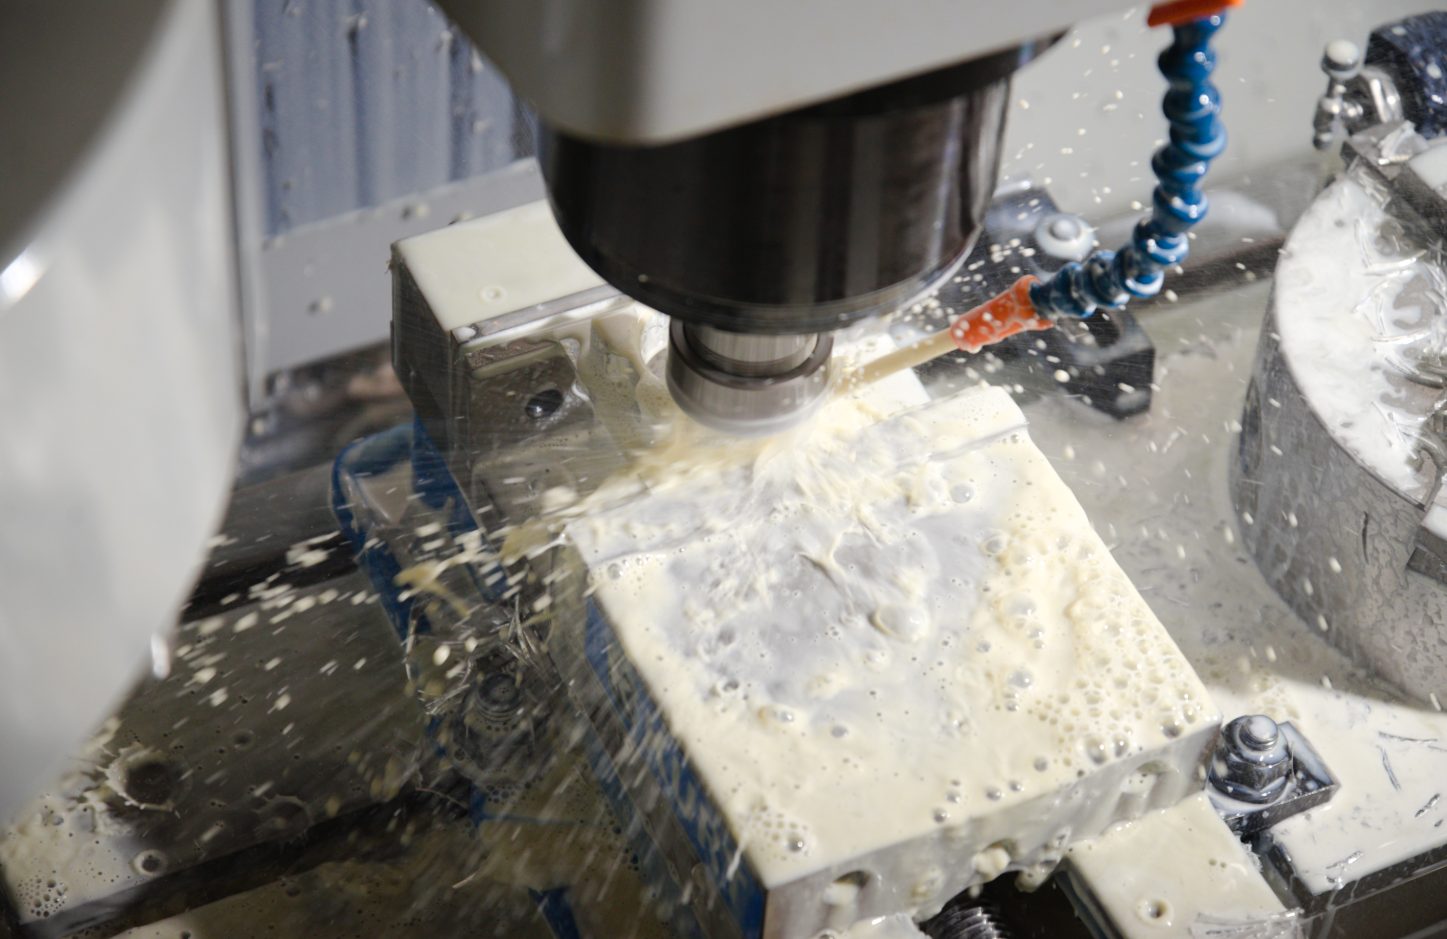
The fabrication process at Ascension Robotics brings designs to life through waterjet cutting, CNC machining, and resin molding. Engineers gain hands-on experience assembling parts with professional tools, as well as developing electronics through PCB soldering, control system integration, and precise wiring management to ensure reliable robot performance.
Embedded Programming
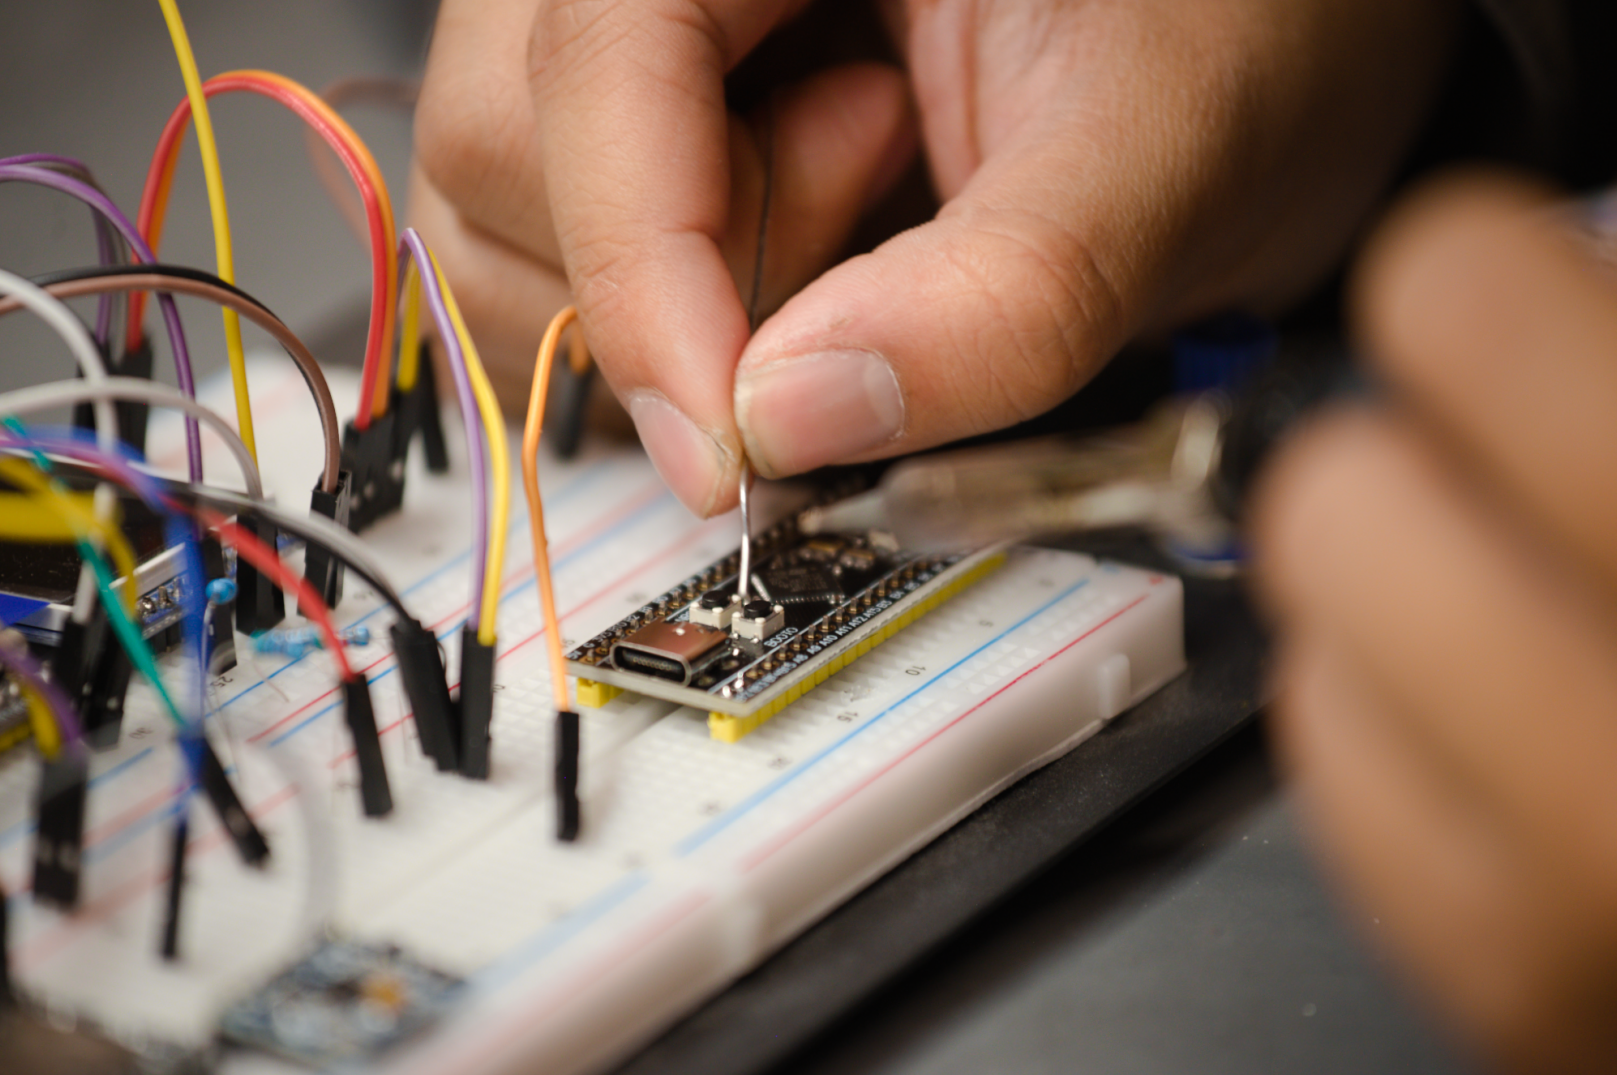
The embedded controls team programs the robots using STM32CubeIDE and C programming. Our team makes custom CAN libraries and creates our own subfunctions that can be used globally across the robots for motor controls. We create optimized PIDS for unique motor situations and rapidly test code with robots on hand.
Computer Vision
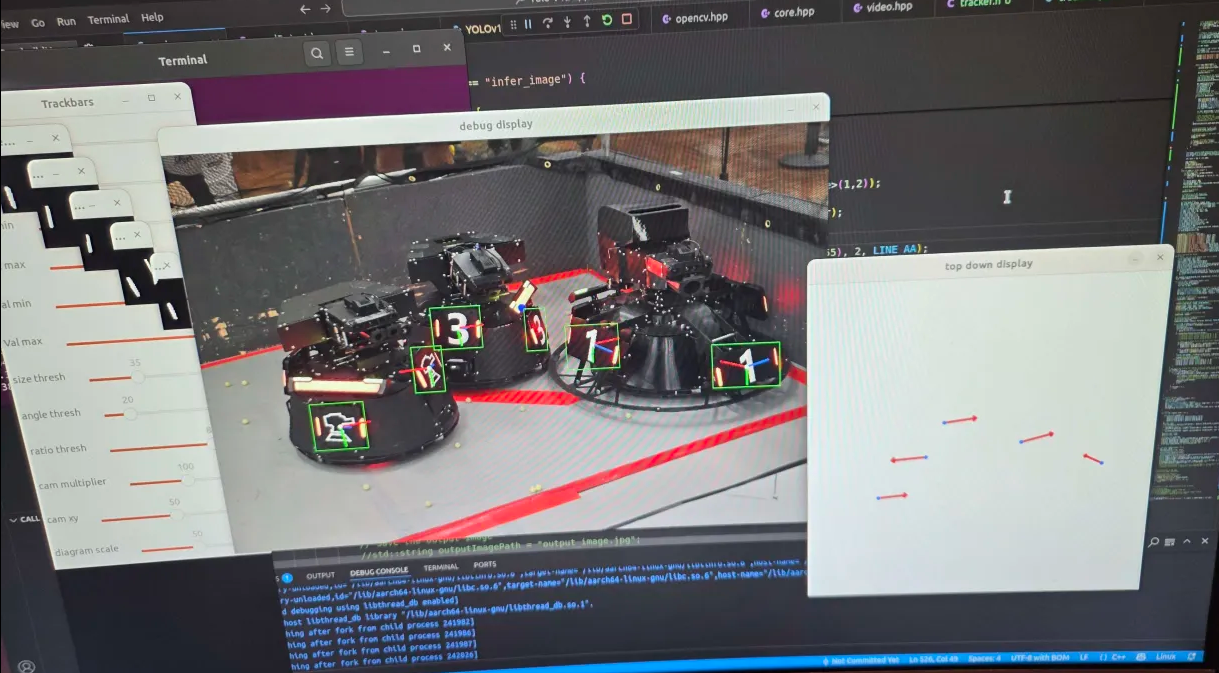
The computer vision team develops custom machine learning detection models to track enemy units. These models enable the robots to aim at enemies on their own if necessary. The team also develops pathfinding algorithms for the sentry robot, allowing it to operate without human intervention by locating objects and the field using a LiDAR.